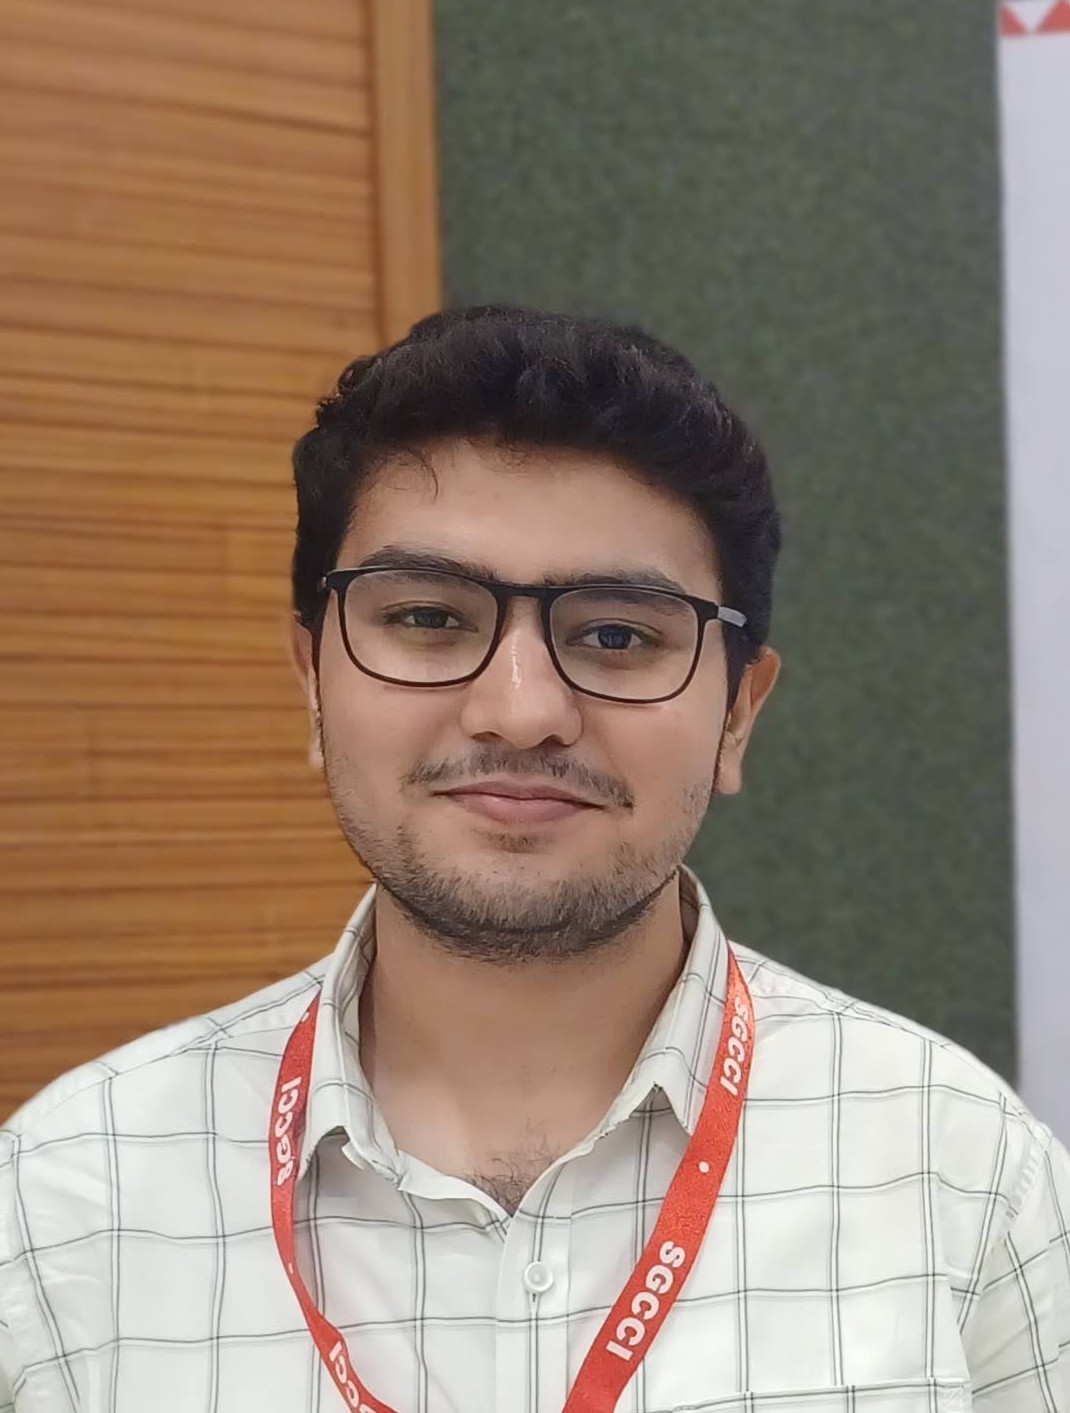
Lomash Relia
Robotics Systems Engineer
Perception → Control → Deployment
I build and deploy perception-driven robotic systems that operate outside the simulator.
My work integrates vision, control theory, embedded computation, and hardware-level system design - moving from mathematical modeling to real-world execution under power, latency, and reliability constraints.
Currently pursuing M.Tech in Autonomous Systems and Machine Intelligence at ABV–IIITM Gwalior.
Engineering Focus
-
Vision-Based Closed-Loop Control
Image-Based Visual Servoing (IBVS), perception-to-actuation pipelines, stability-aware control -
Robotic Hardware Integration
3D-printed fabrication, serial bus servos, power architecture design, calibration -
Edge AI Deployment
Model optimization, quantization, real-time inference on embedded platforms -
Simulation-to-Real Validation
System-level testing across MuJoCo simulation and physical robotic platforms
How I Work
- I design full robotic stacks - not isolated ML models
- I validate control pipelines on physical hardware
- I optimize systems under real compute and power constraints
- I focus on reliability, stability, and deployability
Experience Snapshot
- Research Intern - Space Applications Centre (ISRO)
- Springer & IEEE-published research
- Dual-arm robotic fabrication and actuator-level integration
- Edge AI rover system deployed on Raspberry Pi
Explore My Work
→ Projects - Control pipelines, hardware systems, deployment validation
→ Research - Publications and thesis work
→ Download CV
Seeking Robotics R&D / Autonomous Systems Engineer roles in physical AI, space robotics, and perception-driven control systems.